rm_calibration_controllers::MechanicalCalibrationController Class Reference
#include <mechanical_calibration_controller.h>
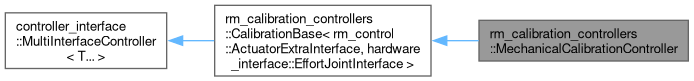
Inheritance diagram for rm_calibration_controllers::MechanicalCalibrationController:
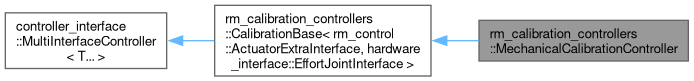
Collaboration diagram for rm_calibration_controllers::MechanicalCalibrationController:
Public Member Functions | |
| MechanicalCalibrationController ()=default | |
| bool | init (hardware_interface::RobotHW *robot_hw, ros::NodeHandle &root_nh, ros::NodeHandle &controller_nh) override |
| Get necessary params from param server. Init joint_calibration_controller. | |
| void | update (const ros::Time &time, const ros::Duration &period) override |
| Execute corresponding action according to current calibration controller state. | |
 Public Member Functions inherited from rm_calibration_controllers::CalibrationBase< rm_control::ActuatorExtraInterface, hardware_interface::EffortJointInterface > | |
| CalibrationBase ()=default | |
| bool | init (hardware_interface::RobotHW *robot_hw, ros::NodeHandle &root_nh, ros::NodeHandle &controller_nh) override |
| Get necessary params from param server. Init joint_calibration_controller. | |
| void | starting (const ros::Time &time) override |
| Switch all of the actuators state to INITIALIZED. | |
| void | stopping (const ros::Time &time) override |
Additional Inherited Members | |
| Protected Types inherited from rm_calibration_controllers::CalibrationBase< rm_control::ActuatorExtraInterface, hardware_interface::EffortJointInterface > | |
| enum | State |
| Protected Member Functions inherited from rm_calibration_controllers::CalibrationBase< rm_control::ActuatorExtraInterface, hardware_interface::EffortJointInterface > | |
| bool | isCalibrated (control_msgs::QueryCalibrationState::Request &req, control_msgs::QueryCalibrationState::Response &resp) |
| Provide a service to know the state of target actuators. | |
| Protected Attributes inherited from rm_calibration_controllers::CalibrationBase< rm_control::ActuatorExtraInterface, hardware_interface::EffortJointInterface > | |
| ros::ServiceServer | is_calibrated_srv_ |
| int | state_ |
| double | velocity_search_ |
| bool | calibration_success_ |
| rm_control::ActuatorExtraHandle | actuator_ |
| effort_controllers::JointVelocityController | velocity_ctrl_ |
| effort_controllers::JointPositionController | position_ctrl_ |
Constructor & Destructor Documentation
◆ MechanicalCalibrationController()
|
default |
Member Function Documentation
◆ init()
|
override |
Get necessary params from param server. Init joint_calibration_controller.
Get params from param server and check whether these params are set.Init JointVelocityController.Check whether threshold is set correctly.
- Parameters
-
robot_hw The robot hardware abstraction. root_nh A NodeHandle in the root of the controller manager namespace. This is where the ROS interfaces are setup (publishers, subscribers, services). controller_nh A NodeHandle in the namespace of the controller. This is where the controller-specific configuration resides.
- Returns
- True if init successful, false when failed.
◆ update()
|
override |
Execute corresponding action according to current calibration controller state.
Execute corresponding action according to current joint state. If INITIALIZED, target joint will be set a vel_search_ and countdown_ to move, and switch state to MOVING. If MOVING, target joint will move until current velocity lower than threshold last for a while, and switch state to CALIBRATED. If CALIBRATED, target joint velocity will be set to zero and wait for next command.
- Parameters
-
time The current time. period The time passed since the last call to update.
The documentation for this class was generated from the following files:
- rm_calibration_controllers/include/rm_calibration_controllers/mechanical_calibration_controller.h
- rm_calibration_controllers/src/mechanical_calibration_controller.cpp
Generated by
 1.12.0