rm_controllers
Loading...
Searching...
No Matches
rm_calibration_controllers::CalibrationBase< T > Class Template Reference

#include <calibration_base.h>

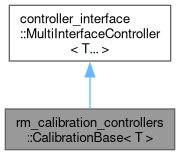
Inheritance diagram for rm_calibration_controllers::CalibrationBase< T >:
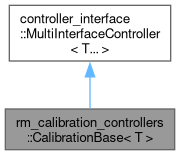
Collaboration diagram for rm_calibration_controllers::CalibrationBase< T >:

Public Member Functions

 CalibrationBase ()=default
 
bool init (hardware_interface::RobotHW *robot_hw, ros::NodeHandle &root_nh, ros::NodeHandle &controller_nh) override
 Get necessary params from param server. Init joint_calibration_controller.
 
void starting (const ros::Time &time) override
 Switch all of the actuators state to INITIALIZED.
 
void stopping (const ros::Time &time) override
 

Protected Types

enum  State { INITIALIZED , CALIBRATED }
 

Protected Member Functions

bool isCalibrated (control_msgs::QueryCalibrationState::Request &req, control_msgs::QueryCalibrationState::Response &resp)
 Provide a service to know the state of target actuators.
 

Protected Attributes

ros::ServiceServer is_calibrated_srv_
 
int state_ {}
 
double velocity_search_ {}
 
bool calibration_success_ = false
 
rm_control::ActuatorExtraHandle actuator_
 
effort_controllers::JointVelocityController velocity_ctrl_
 
effort_controllers::JointPositionController position_ctrl_
 

Member Enumeration Documentation

◆ State

template<typename... T>
enum rm_calibration_controllers::CalibrationBase::State
protected
Enumerator
INITIALIZED 
CALIBRATED 

Constructor & Destructor Documentation

◆ CalibrationBase()

template<typename... T>
rm_calibration_controllers::CalibrationBase< T >::CalibrationBase ( )
default

Member Function Documentation

◆ init()

template<typename... T>
bool rm_calibration_controllers::CalibrationBase< T >::init ( hardware_interface::RobotHW * robot_hw,
ros::NodeHandle & root_nh,
ros::NodeHandle & controller_nh )
override

Get necessary params from param server. Init joint_calibration_controller.

Get params from param server and check whether these params are set.Init JointVelocityController.Check whether threshold is set correctly.

Parameters
robot_hwThe robot hardware abstraction.
root_nhA NodeHandle in the root of the controller manager namespace. This is where the ROS interfaces are setup (publishers, subscribers, services).
controller_nhA NodeHandle in the namespace of the controller. This is where the controller-specific configuration resides.
Returns
True if init successful, false when failed.

◆ isCalibrated()

template<typename... T>
bool rm_calibration_controllers::CalibrationBase< T >::isCalibrated ( control_msgs::QueryCalibrationState::Request & req,
control_msgs::QueryCalibrationState::Response & resp )
protected

Provide a service to know the state of target actuators.

When requesting to this server, it will return respond about whether target actuators has been calibrated.

Parameters
reqThe request of knowing the state of target actuators.
respThe respond included the state of target actuators.
Returns
True if get respond successfully, false when failed.

◆ starting()

template<typename... T>
void rm_calibration_controllers::CalibrationBase< T >::starting ( const ros::Time & time)
override

Switch all of the actuators state to INITIALIZED.

Switch all of the actuator state to INITIALIZED in order to restart the calibration.

Parameters
timeThe current time.

◆ stopping()

template<typename... T>
void rm_calibration_controllers::CalibrationBase< T >::stopping ( const ros::Time & time)
override

Member Data Documentation

◆ actuator_

template<typename... T>
rm_control::ActuatorExtraHandle rm_calibration_controllers::CalibrationBase< T >::actuator_
protected

◆ calibration_success_

template<typename... T>
bool rm_calibration_controllers::CalibrationBase< T >::calibration_success_ = false
protected

◆ is_calibrated_srv_

template<typename... T>
ros::ServiceServer rm_calibration_controllers::CalibrationBase< T >::is_calibrated_srv_
protected

◆ position_ctrl_

template<typename... T>
effort_controllers::JointPositionController rm_calibration_controllers::CalibrationBase< T >::position_ctrl_
protected

◆ state_

template<typename... T>
int rm_calibration_controllers::CalibrationBase< T >::state_ {}
protected

◆ velocity_ctrl_

template<typename... T>
effort_controllers::JointVelocityController rm_calibration_controllers::CalibrationBase< T >::velocity_ctrl_
protected

◆ velocity_search_

template<typename... T>
double rm_calibration_controllers::CalibrationBase< T >::velocity_search_ {}
protected

The documentation for this class was generated from the following files: